ME 2110: Fallen Kingdom
Back to portfolio
The most infamously time-consuming class at Georgia Tech: making an autonomous competition robot
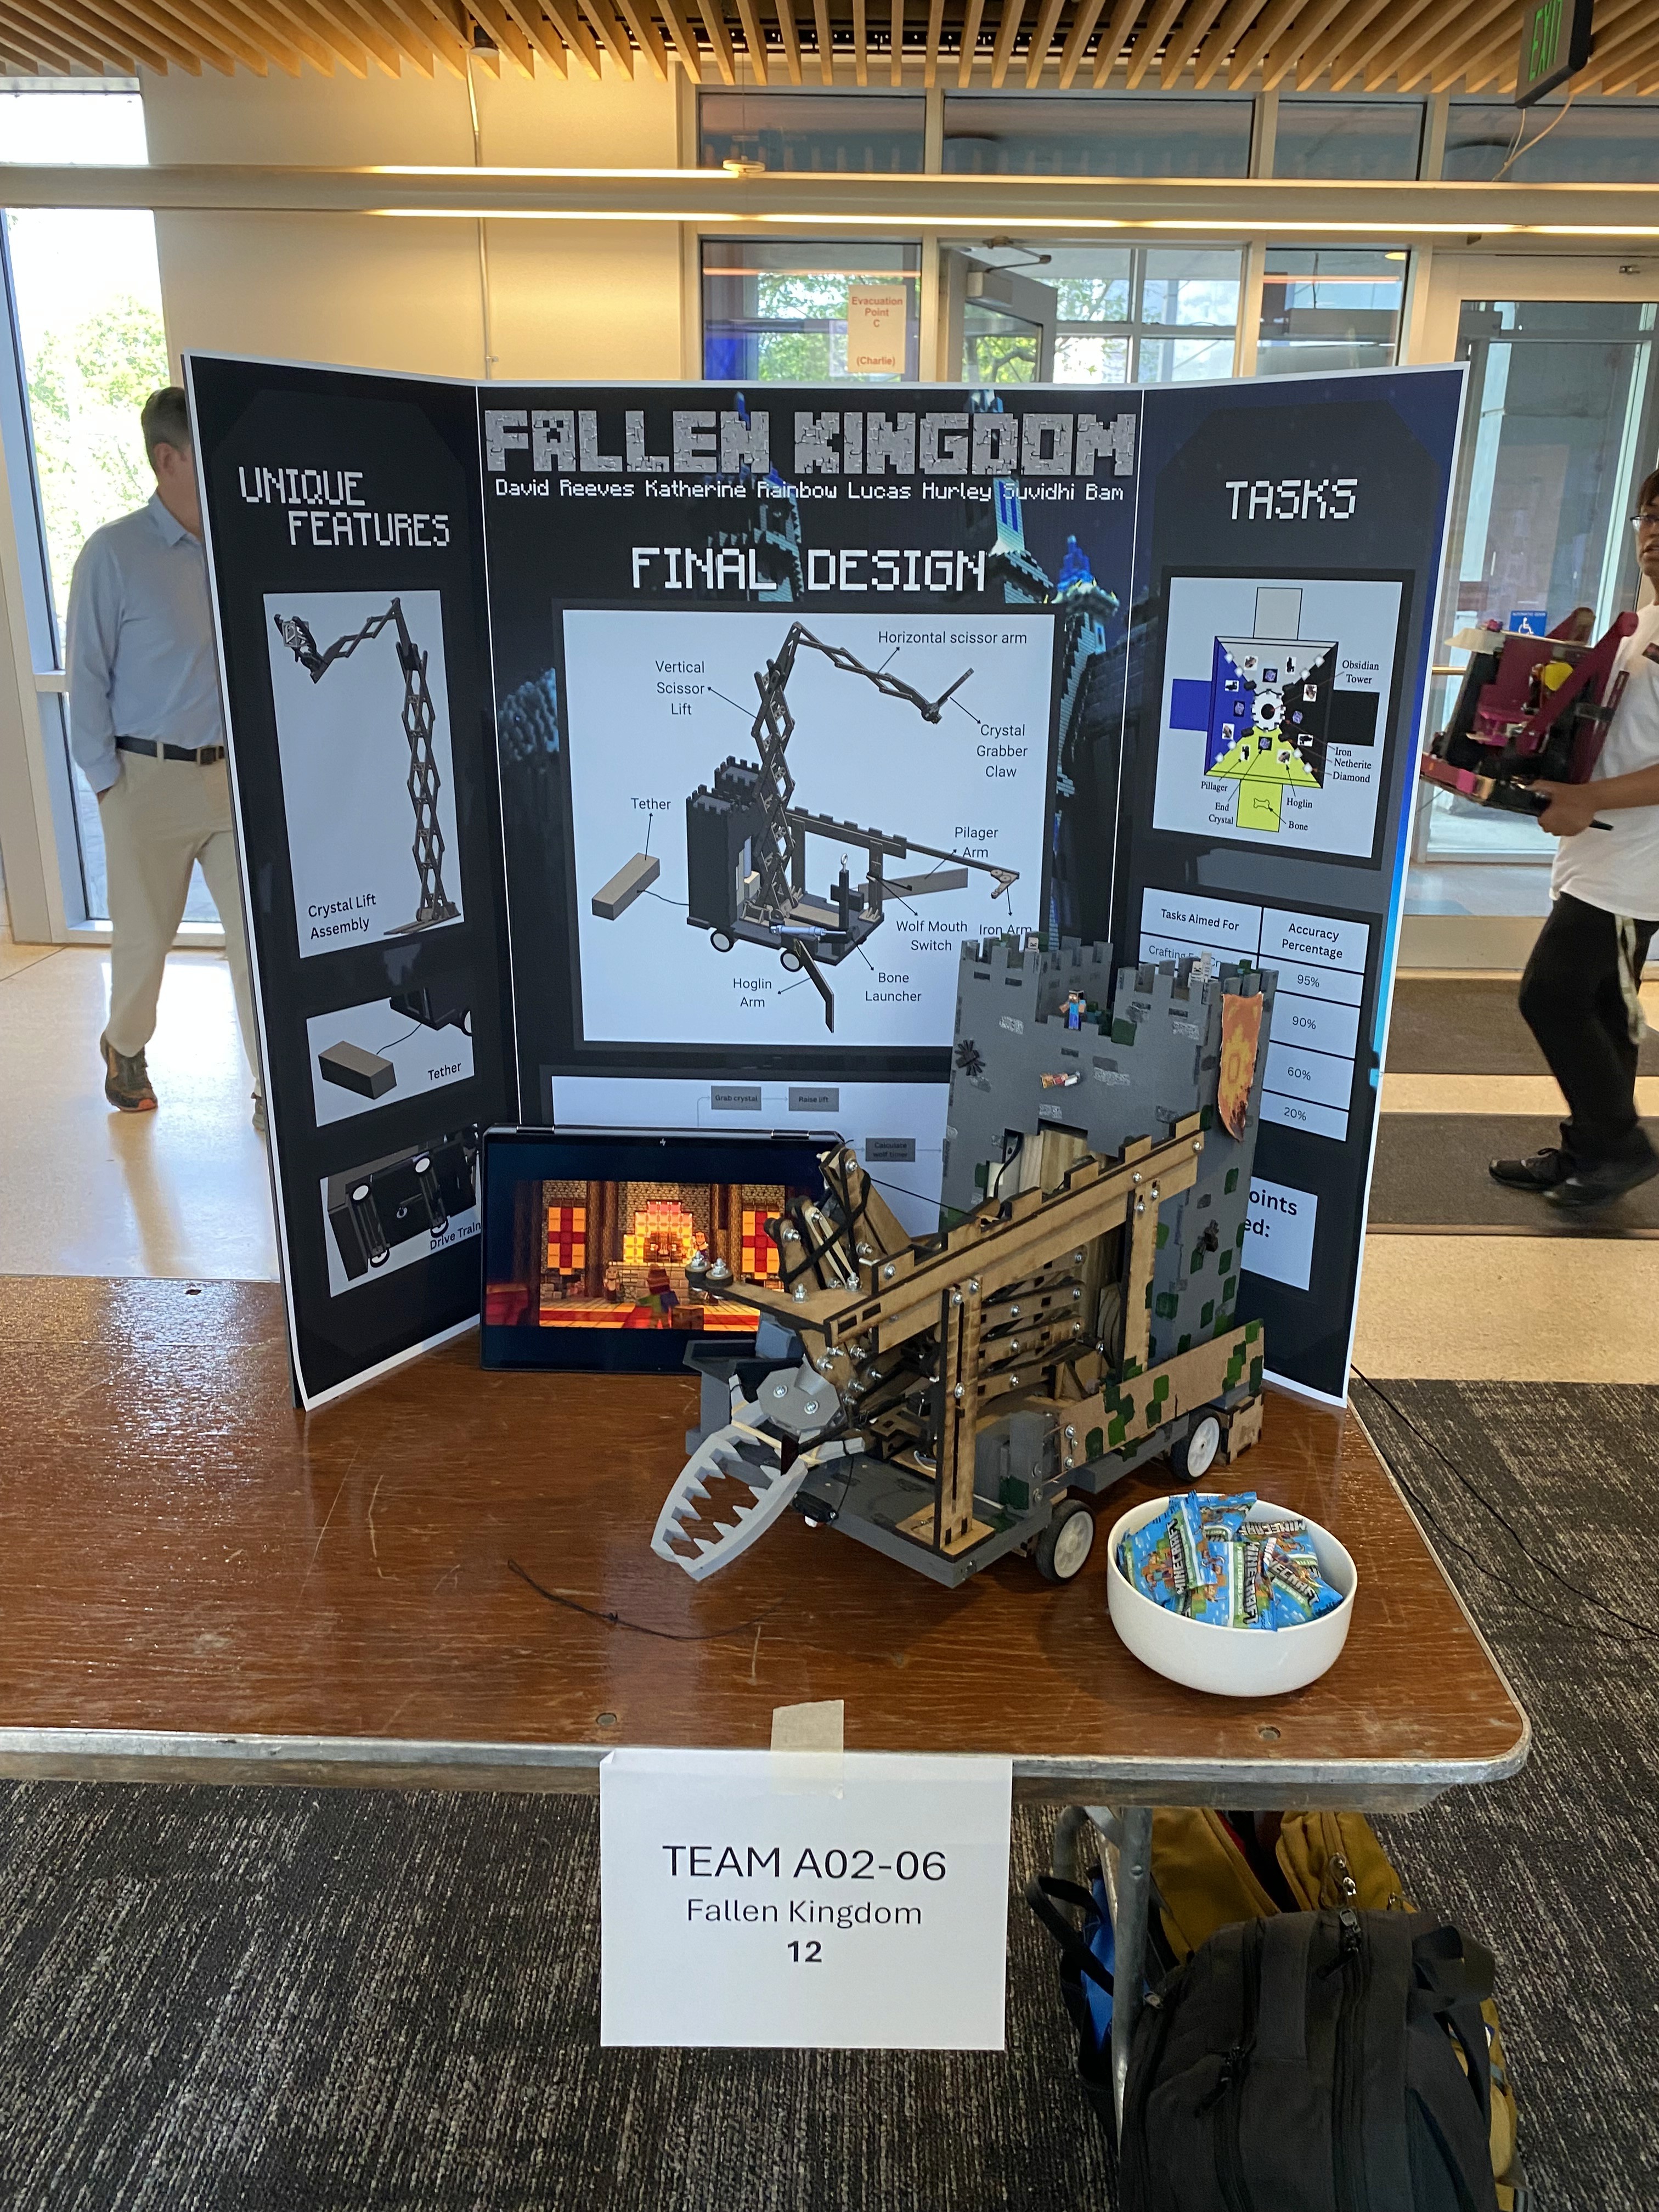
There were five tasks to complete in this competition. Points were earned by knocking evil creatures out of the zone, raking diamonds in, knocking iron off the tower, putting a bone into a slot, and grabbing and raising an end crystal above the central tower.

Even after driving all the way up to the center of the track, the end crystal still needed to be raised up 28" and moved forward another 12". I used SOLIDWORKS to design a compound scissor lift to first raise, and then extend, the crystal. I laser cut the design from MDF and actuated it with a DC motor winding a spool. Our group was one of the only ones to successfully complete this task.

Since the Arduino Uno we were using to program the robot only had a small amount of storage space, I kept the code very simple. Aside from an emergency shutdown switch and protocol to maximize points in the event of a malfunction, the main section was just a simple timer to sequentially trigger the mechanisms. The only inputs were the track power, the IR sensor, and the bone switch.


After delegating tasks with my team, I ended up with the jobs of machine locomotion, iron gathering, raising the end crystal, triggering the bone launcher, and programming. For locomotion, I designed a simple bracket assembly driven by a DC motor. I added a weighted tether to prevent the bot from slipping down the ramp and losing control, and used an IR sensor to control the driving distance

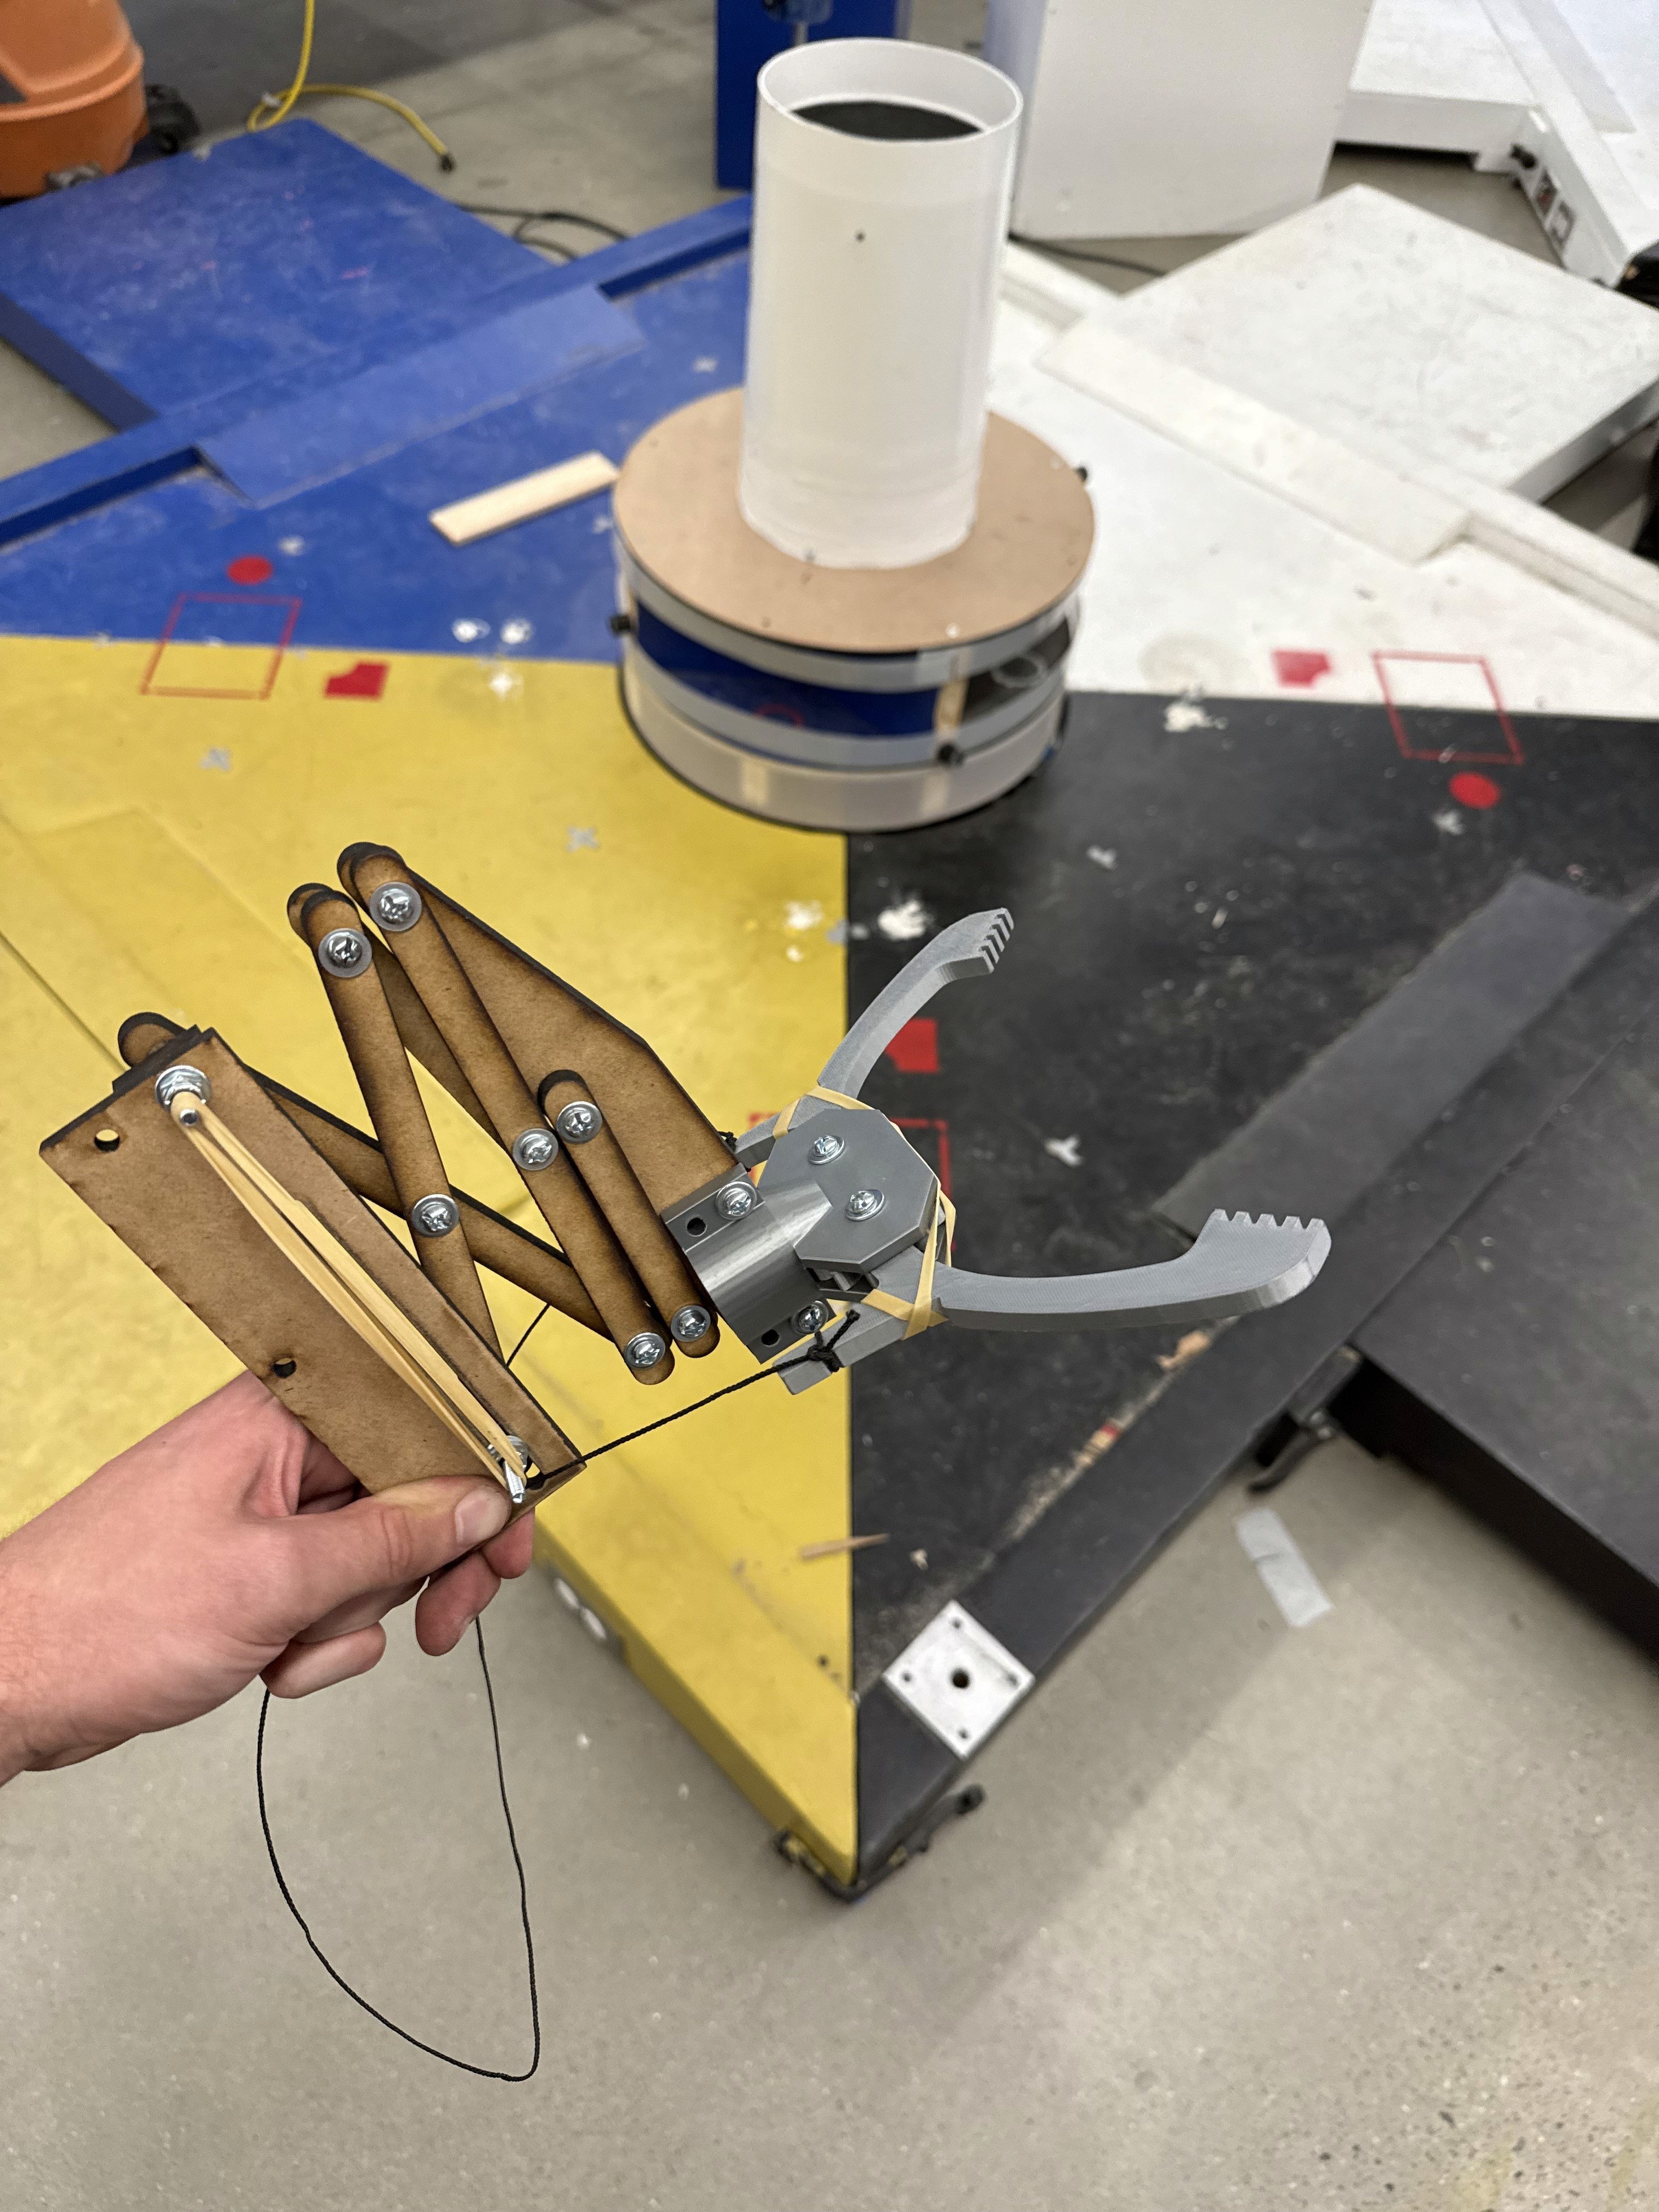
To gather the iron blocks from the rotating central tower, I designed a rubber band actuated extending roller arm. The wheel on the end would be pressed against the tower and the blocks would follow the curve of the arm and drop into our zone. I also put a switch to trigger the bone launcher onto this assembly with a long arm to be toggled by the knobs on the rotating centerpiece.

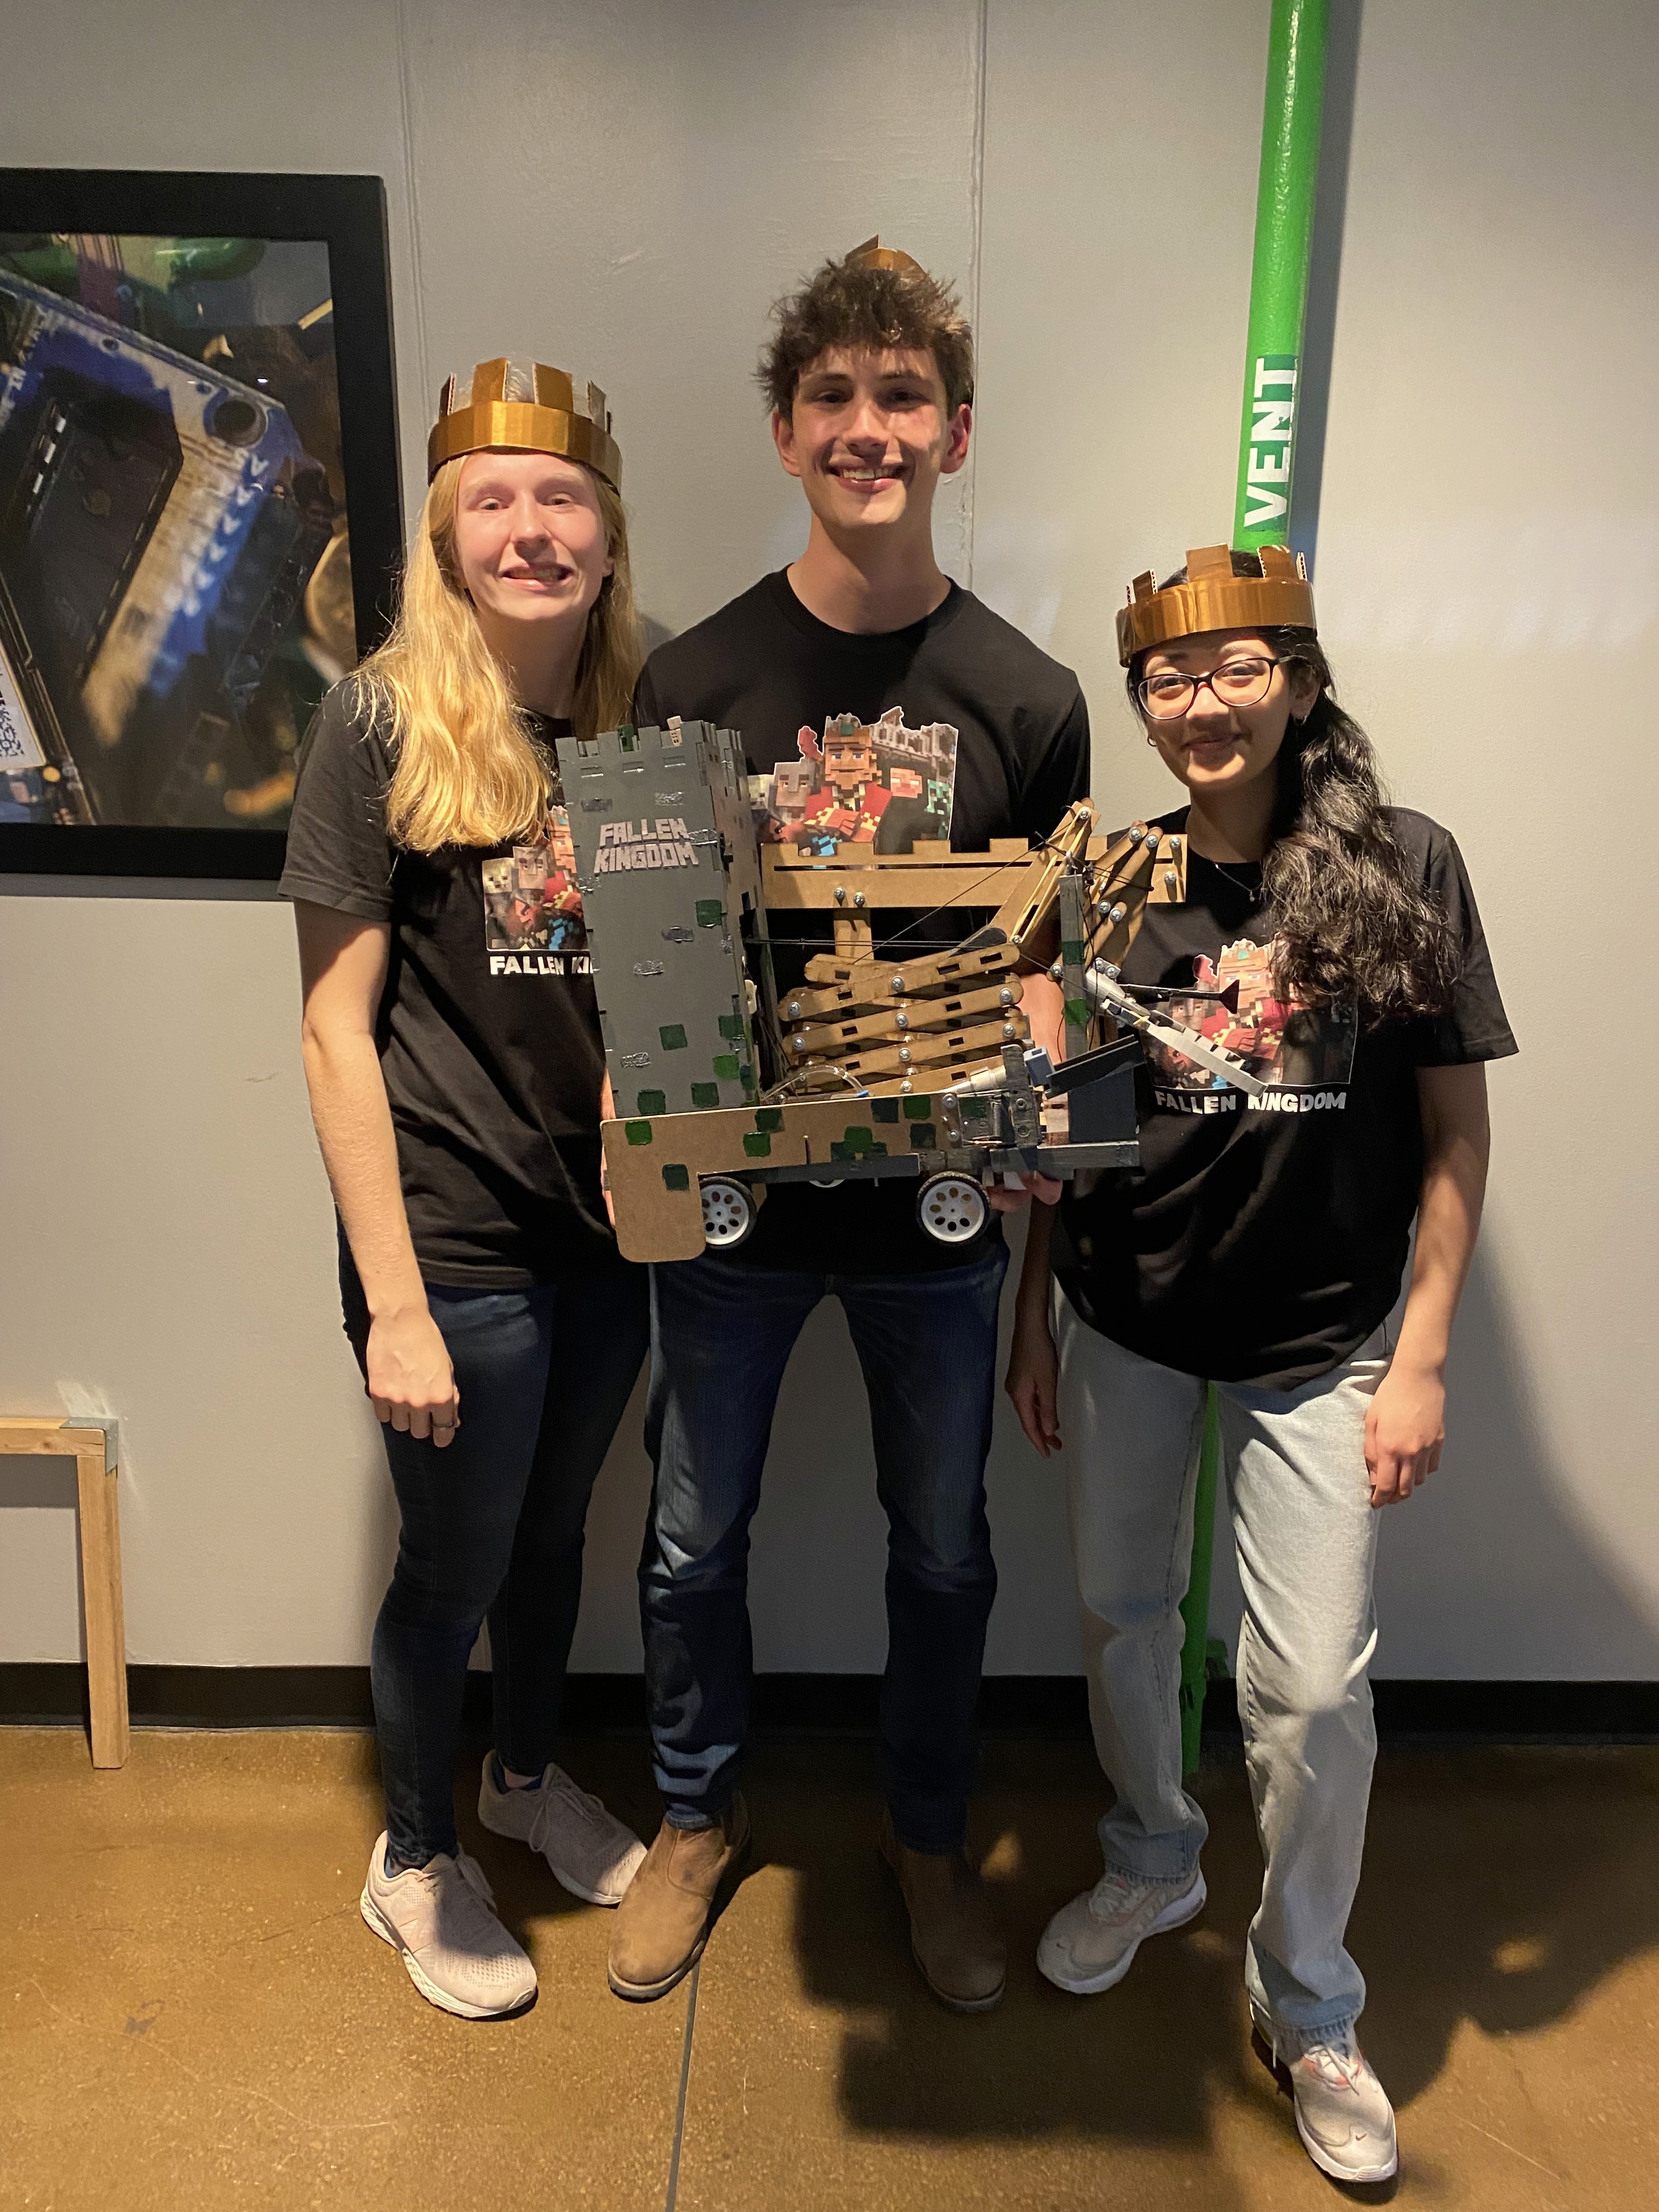
We easily made it to the semifinals, averaging the highest score of the 56 teams in the competition. Everything looked perfect until our standard-issued power cord frayed without us noticing. We watched, heartbroken, as our robot sat motionless. The team that looked almost certain to win the competition had just been taken down by a single wire.
Project Gallery